01
Autonomous crop harvesting
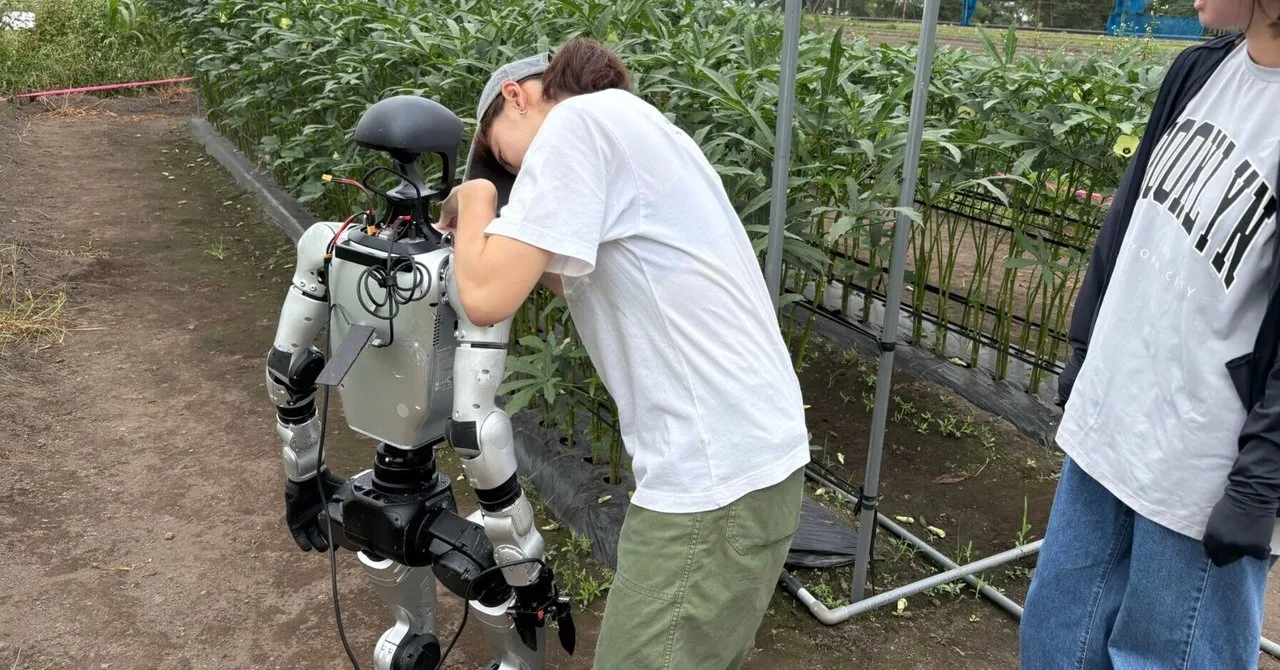
At a farm in Kagoshima, a humanoid autonomously grasps and harvests okra. The motor skill was trained from human demonstrations with imitation learning (ACT) — the robot acts on its own, without teleoperation.
See humanoid robots in agriculture
- Imitation learning (ACT)
- Motor skills trained from human demonstrations.
- Real field
- Implemented at a working farm, not a lab.
- Autonomous
- Grasping and harvesting without teleoperation.